115 m AGL end home 500 m N

Drone survey planner

Know the size of the job before you fly it.

Swathwise is a map you draw on. Outline the ground or pick a road, choose the aircraft and the sensor, and it tells you the square miles, the flight time and the battery sets. Then it writes the flight routes with the terrain built in, places the ground control, and gives the crew directions to the launch point.

Size
1.279sq mi
Time in the air
57min
Battery sets
2

A sample block as Swathwise plans it. The flight lines, the time and the battery sets are the planner's own output; the ground drawn behind them is made up.

  1. Mark the ground

    Start from whatever you have: the client's file, a parcel, a road, or a sketch on the map.

    Draw it or import it
    Sketch areas and corridors on the map, or drop in the boundary the client sent as KMZ, KML or GeoJSON. A polygon becomes an area, a line becomes a corridor, and one job can hold as many as it needs.
    Pick a road
    Click where a corridor starts and where it ends. It follows the roads between, turns at the junctions and takes the road's name. Drag the ends, set an exact length, or split it and cut a town out. United States only.
    Pick parcels
    Click lots on the map and each becomes a flight area with the lot's own boundary, named by its site address. Merge the ones that touch. Jackson, Josephine and Klamath counties in Oregon, San Diego County and all of California so far.
    Tribal lands, states and counties
    Every federally recognised reservation, rancheria and trust land boundary is built in and works with no connection. Click one and use it as the flight area.
    Places
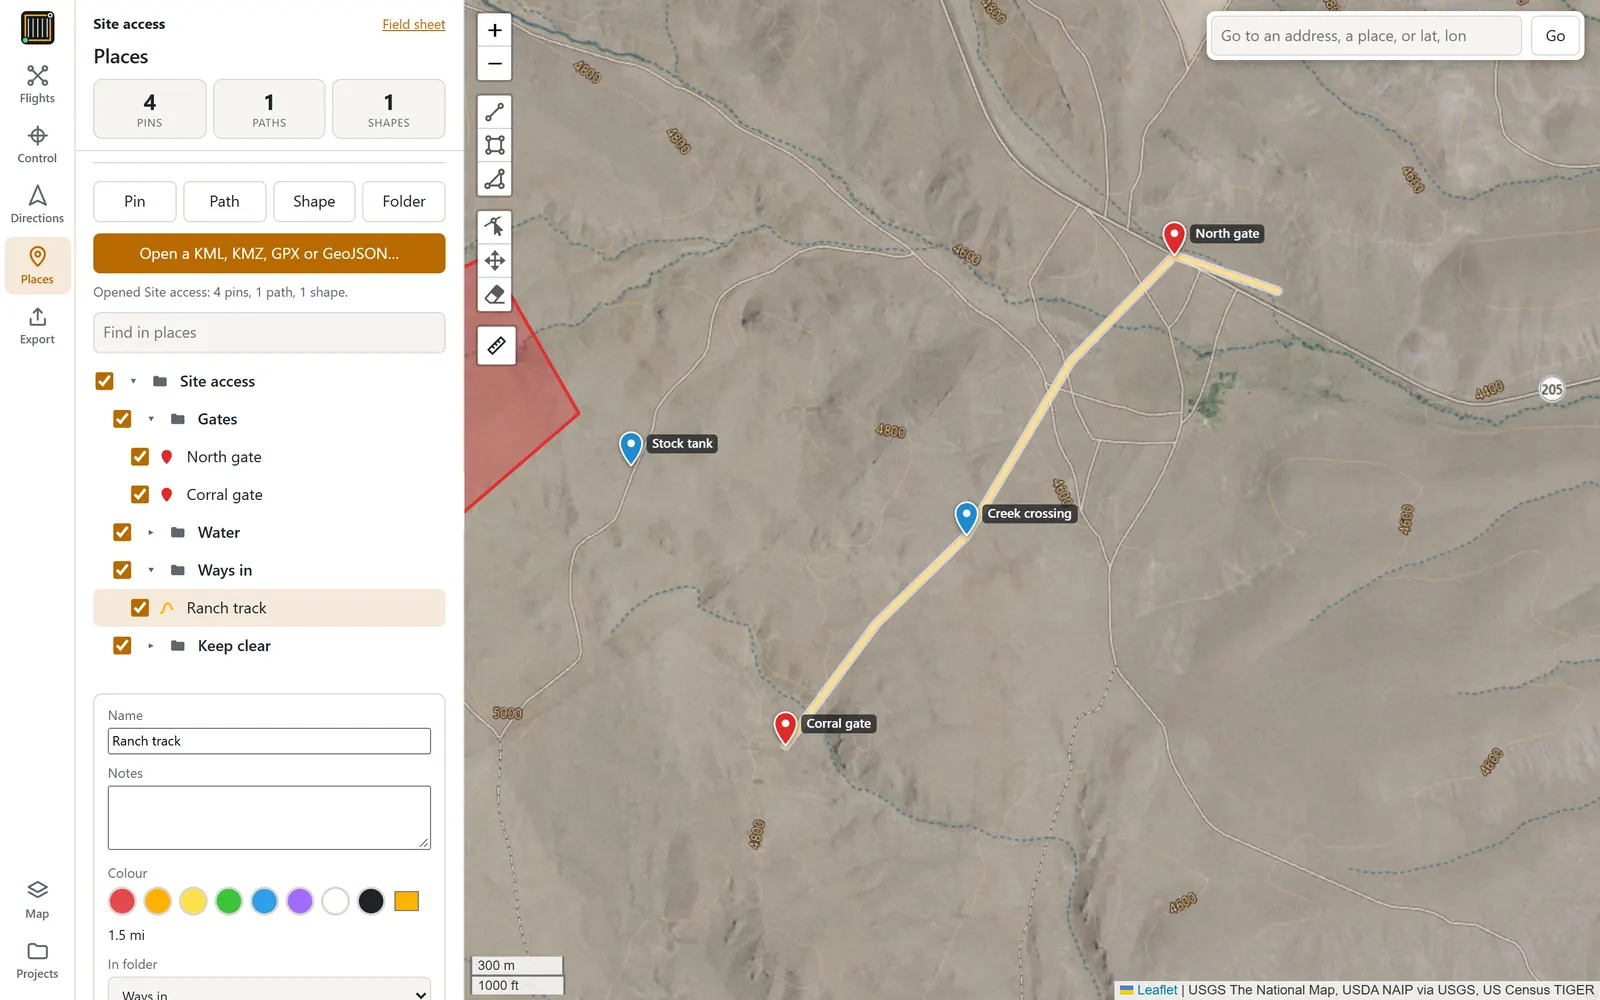
    Open KML, KMZ, GPX and GeoJSON files with their folders, colours and notes intact, make your own pins, paths and shapes, and save them back out.
    Measure
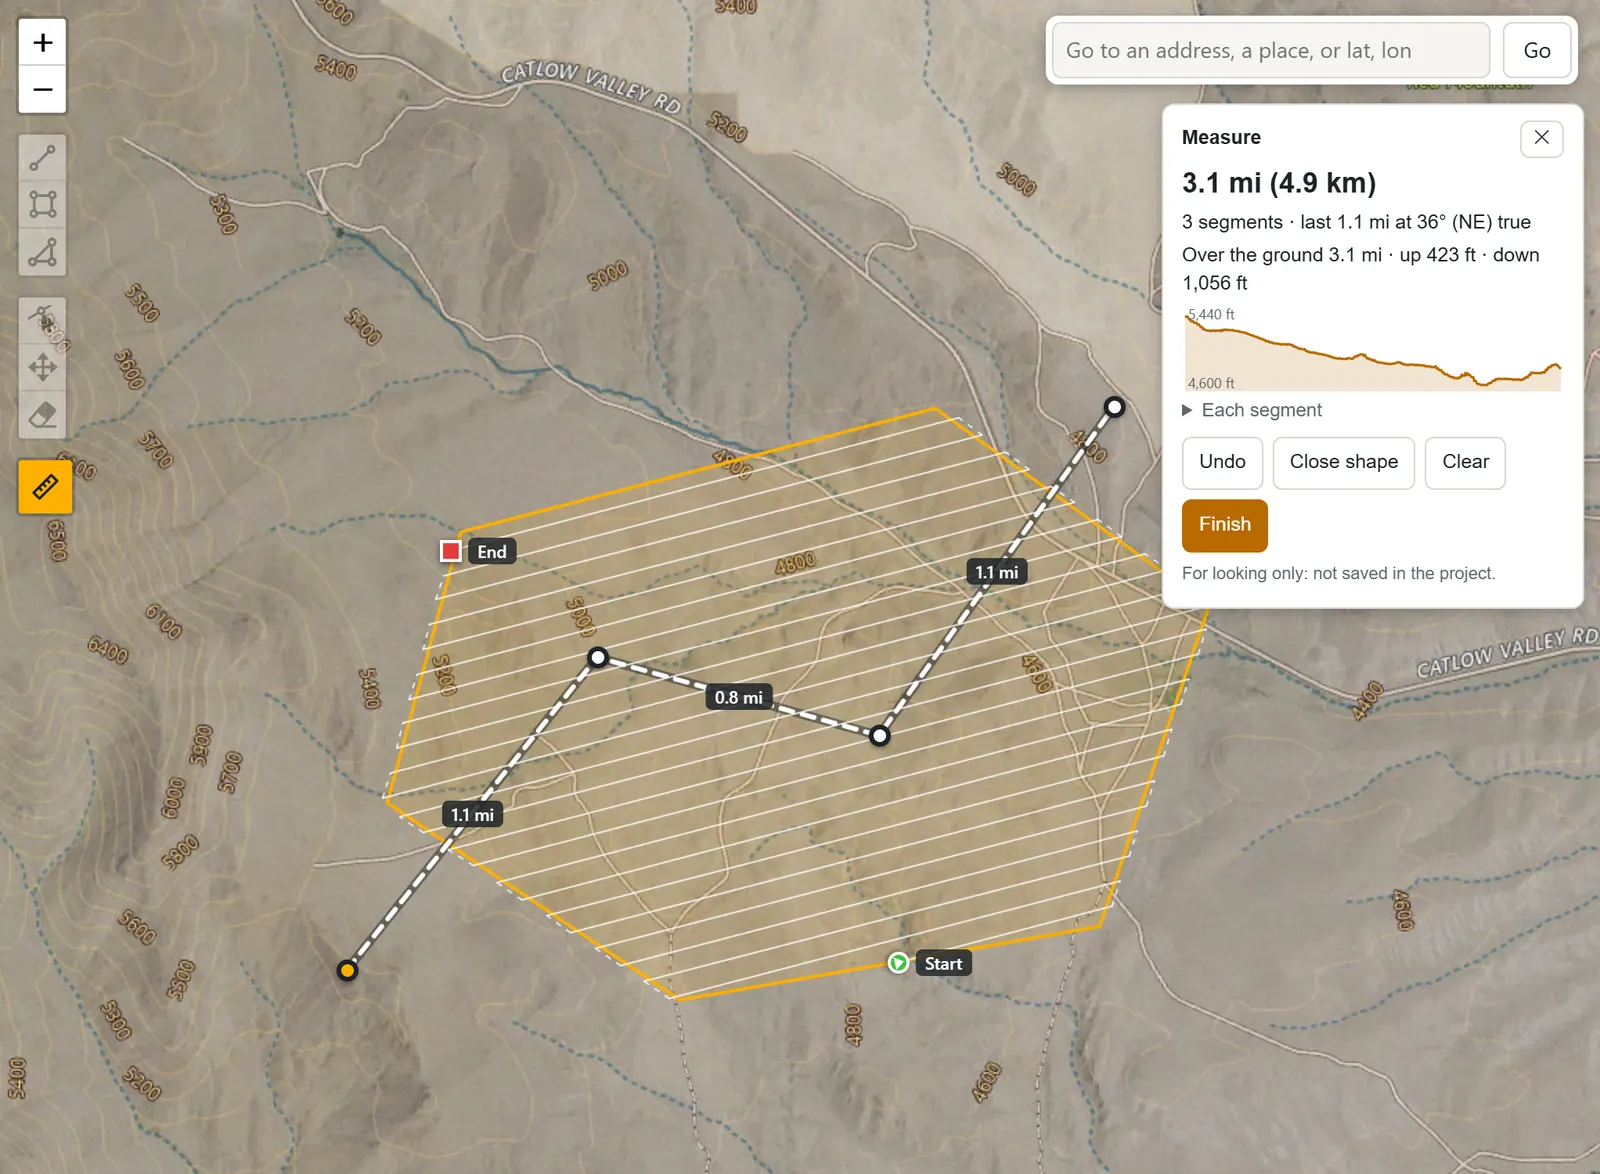
    The ruler on the map gives a line's length and bearings, the climb and drop along the ground, a small profile, and the area if you close the shape.
    Swathwise with the Places section open. A KML file's folders are listed on the left; on the satellite map are red and blue pins, an orange track between two gates and a red keep-clear shape.
    A KML file open in Places: its folders, pins, a track and a keep-clear shape, over United States government imagery.
    The Measure card on the map: 3.1 miles over three segments, with the climb, the drop and a small ground profile.
    Measure, with the ground under the line from the USGS.
  2. Choose the job

    Tell Swathwise what kind of job it is. It works out the height, speed, overlap and scan settings for your aircraft and sensor from the published standard that job is judged against, and shows its working. These are real output, not mock-ups.

    end home 500 m N

    LiDAR · Corridor Common practice, no formal standard

    Fiber — overhead (poles and conductors)

    Poles, attachments and spans for make-ready and pole-loading analysis.

    Matrice 400 + Zenmuse L3

    Judged against: Power Line Systems (PLS-CADD) sample survey specification

    What the job comes to

    Size 2.77 km (1.72 mi) × 60 m
    Flight lines 2 · 5.5 km · 43.6 m apart
    Raw point density about 268 pts/m²
    Time in the air 13 min
    Battery sets 1 · 37.0 usable min each
    In the field, with swaps 13 min

    Settings it worked out

    Height above ground 60 m (197 ft)
    Speed 15 m/s
    Side overlap 50 %
    Scanning Non-repetitive
    Pulse rate 350 kHz
    Returns Hexadeca (16)
    Passes 2 (out and back)
    Show the working

    No formal standard sets lidar density or accuracy for this. The most reused utility survey template (Power Line Systems) asks ≥ 15 points/m², 0.5 ft absolute and 0.35 ft relative accuracy at 95 %, and four returns per pulse. What actually decides it is getting close to thin objects: DJI's band is 10–50 m ABOVE THE LINE, 30–50 m recommended — so on 10–12 m distribution poles, 40–60 m above the ground. DJI's power-line checklists fly this at 12–15 m/s (L2) and 17 m/s (L3) on the non-repetitive scan.

    1. The requirement is 15 pulses/m².
    2. Height 60 m — this product needs the sensor close to what it is measuring.
    3. At 44 m line spacing and 350 kHz, 15 m/s lays down 232 pulses/m² in a single swath — 15× the requirement. Density is not what limits this job, so speed is DJI's figure for this kind of scene.
    end home 200 m N

    Photogrammetry Published standard

    Orthomosaic & planimetric mapping (ASPRS)

    A measurable orthomosaic and the planimetric features drawn from it: edges of pavement, structures, fences, utilities visible from above.

    Matrice 350 RTK + Zenmuse P1

    Judged against: ASPRS Positional Accuracy Standards, Edition 2 Version 2 (2024) — §7.10, §7.14, Table B.4, Addendum III §C, Addendum V §A.4–A.5, Addendum VI §E.2

    What the job comes to

    Size 0.079 sq mi · 51 acres
    Flight lines 16 · 8.8 km · 29.5 m apart
    Ground sample distance 1.44 cm/px · 770 photos
    Time in the air 29 min
    Battery sets 1 · 31.0 usable min each
    In the field, with swaps 29 min

    Settings it worked out

    Lens 35 mm
    Height above ground 115 m (377 ft)
    Speed 7 m/s
    Side overlap 75 %
    Forward overlap 85 %
    Shutter 1/1000 s
    Grids 1
    Show the working

    ASPRS Edition 2 names an accuracy class by its horizontal RMSE and refuses to tie it to GSD. Its Table B.4 offers source imagery of 2.5–5 cm GSD for a 5 cm class and 1.25–2.5 cm for a 2.5 cm class — as a general reference only, and written for large- and medium-format METRIC cameras, which no drone camera here is. This preset holds 2.5 cm. For structure-from-motion processing ASPRS recommends 75–85 % forward and 65–75 % side overlap (Addendum III; its UAS addendum also mentions 80 / 60); this preset is the top of that band, because on this camera forward overlap costs photos, not flight time. An orthomosaic's seamlines may mismatch by no more than twice the class RMSE.

    1. Height 115 m — just under the 400 ft Part 107 limit. The 35 mm lens gives 1.44 cm/px there, inside the 2.5 cm required, so GSD does not limit height.
    2. Each photo covers 118 × 79 m: 75 % side overlap puts the lines 29 m apart, 85 % forward overlap a photo every 11.8 m.
    3. That overlap is what ground LEVEL with the launch point gets. With terrain follow off, ground 20 m higher is closer to the camera and sees 82 / 70 % — and finer pixels, so more blur. Launch from the high ground, or turn Terrain Follow on in Pilot 2.
    4. Speed 7 m/s — motion blur: at a 1/1000 s shutter this holds it to 0.5 px, half the 1 px ASPRS allows. SET 1/1000 s OR FASTER ON THE CAMERA — the route file cannot carry it, and at a slower shutter this speed smears the photos. A faster shutter buys speed back in proportion.

    It also warned

    • The P1's route-file values are unverified: DJI publishes neither its payload value (50) nor the value that names the lens. If the lens value is wrong, Pilot 2 lays the lines out for the other lens. Export one mapping route per lens from Pilot 2 and compare its payloadInfo before trusting a draft KMZ. The estimate itself does not depend on it.

    Every example assumes a site at 4,000 ft, landing at 25 % battery and 10 minutes to swap a battery set. Home is the green point; the ring is where the route ends. Every aircraft, sensor and job type is on the features page.

  3. Read the numbers

    The figures that size the job stay pinned at the top of the screen and change as you do, so you can see what a tighter spec costs before you quote it.

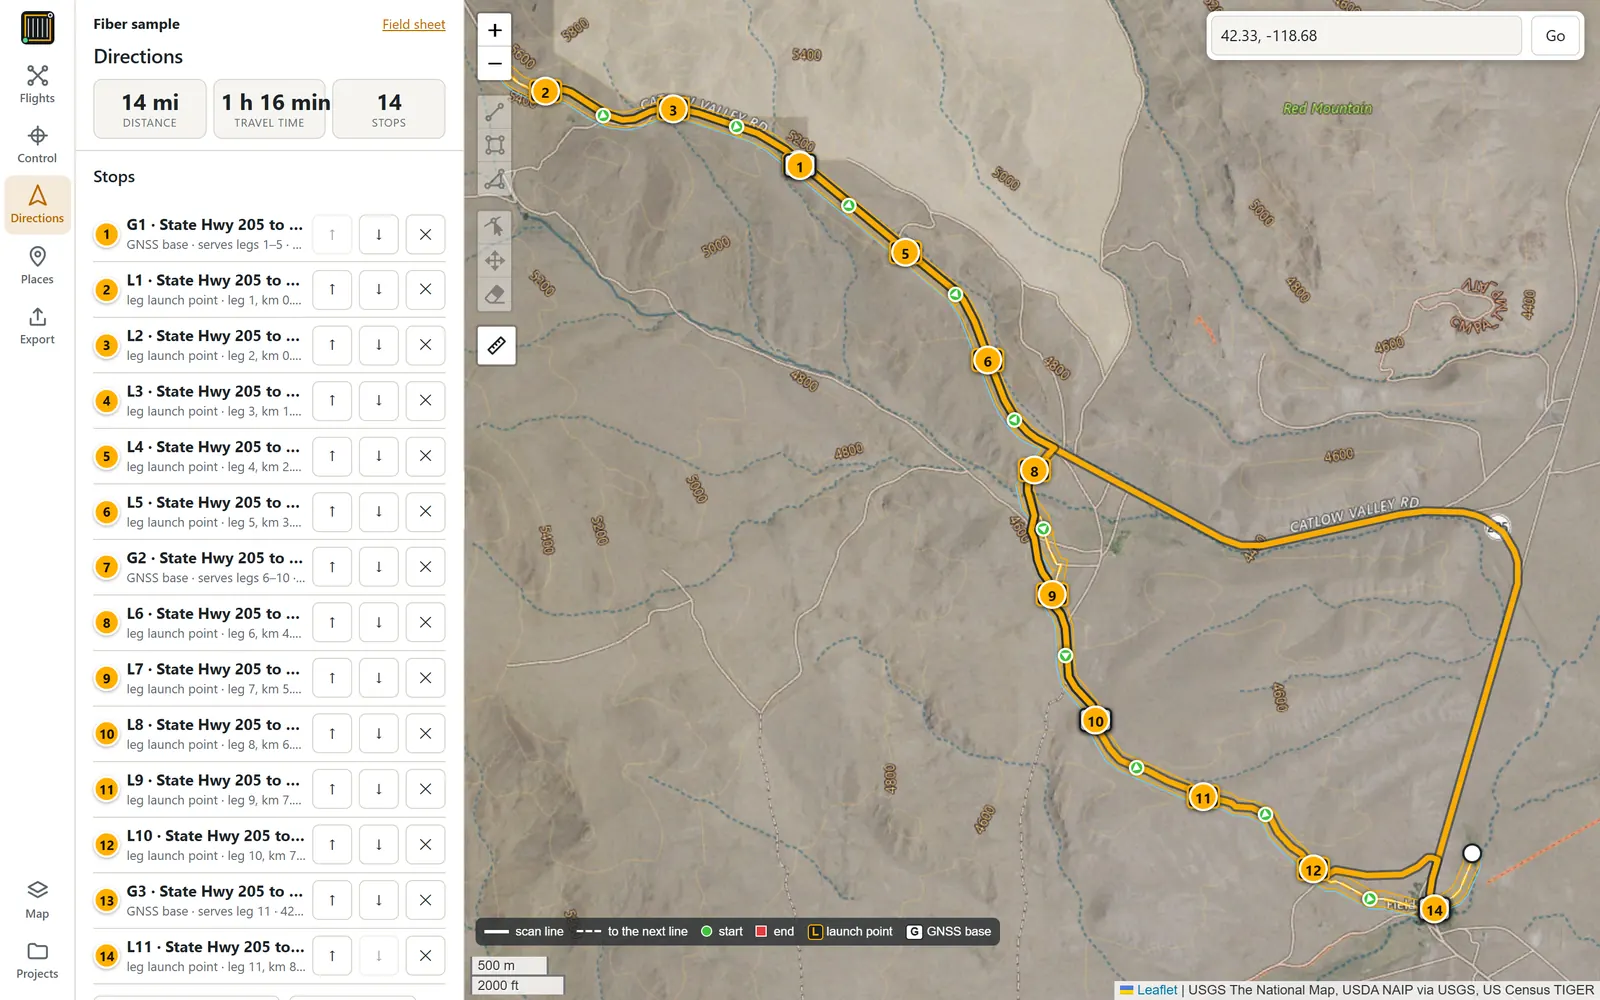
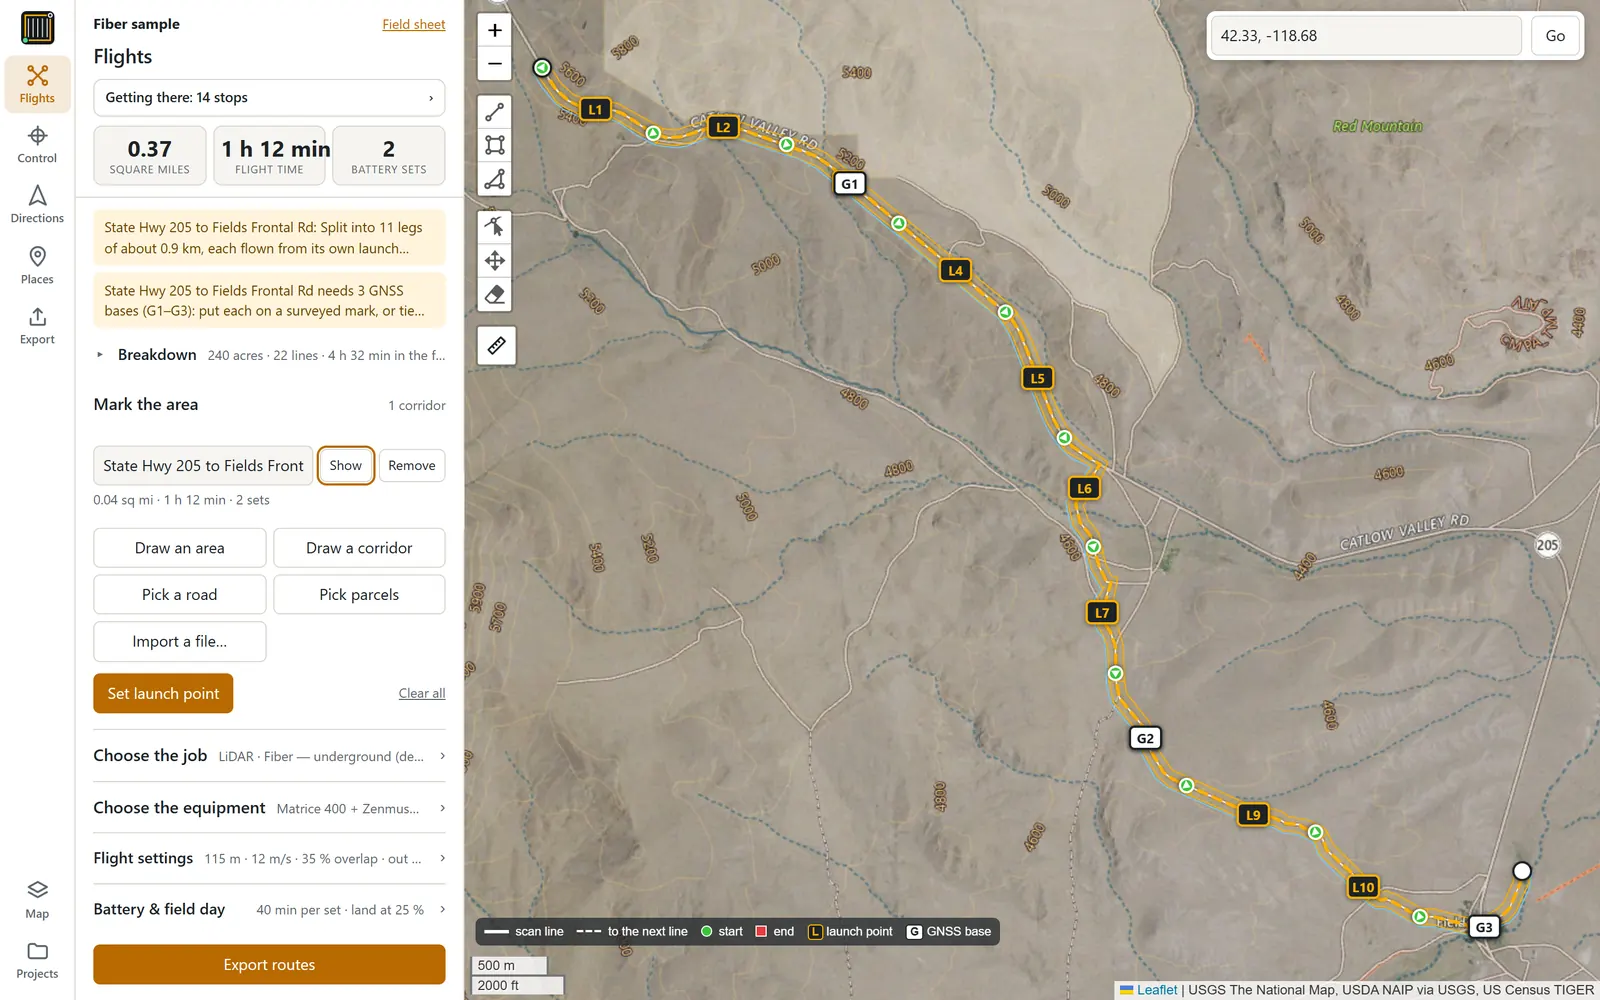
    A fiber corridor along State Highway 205 in Swathwise, split into eleven legs. Launch points L1 to L10 and GNSS bases G1 to G3 are marked along the road on satellite imagery.
    A 6-mile corridor picked along State Highway 205, split into eleven legs, each with its launch point, and three GNSS bases.
    Square miles
    The true area inside the boundary, per block and for the whole job.
    Flight time
    Every flight line and every turn, at the speed and height you set.
    Battery sets
    How many the job takes, at the site's elevation and the reserve you land with, with the ferry out from the launch point charged to every set.
    Long corridors split themselves
    A route too long for one launch point is cut into legs, each with its own route files and launch point. It says what set the length: sight distance, GNSS base reach, base spacing or the battery.
    GNSS bases that stay put
    Bases are placed apart from the launch points, and it works out how far the aircraft can get from one before vertical accuracy slips past the job's target, at the height you are flying.
    One area at a time
    Click any area for its own acres, air time, battery sets, route files and heading. Step through them with the arrow keys and export one on its own.
  4. Plan the ground control

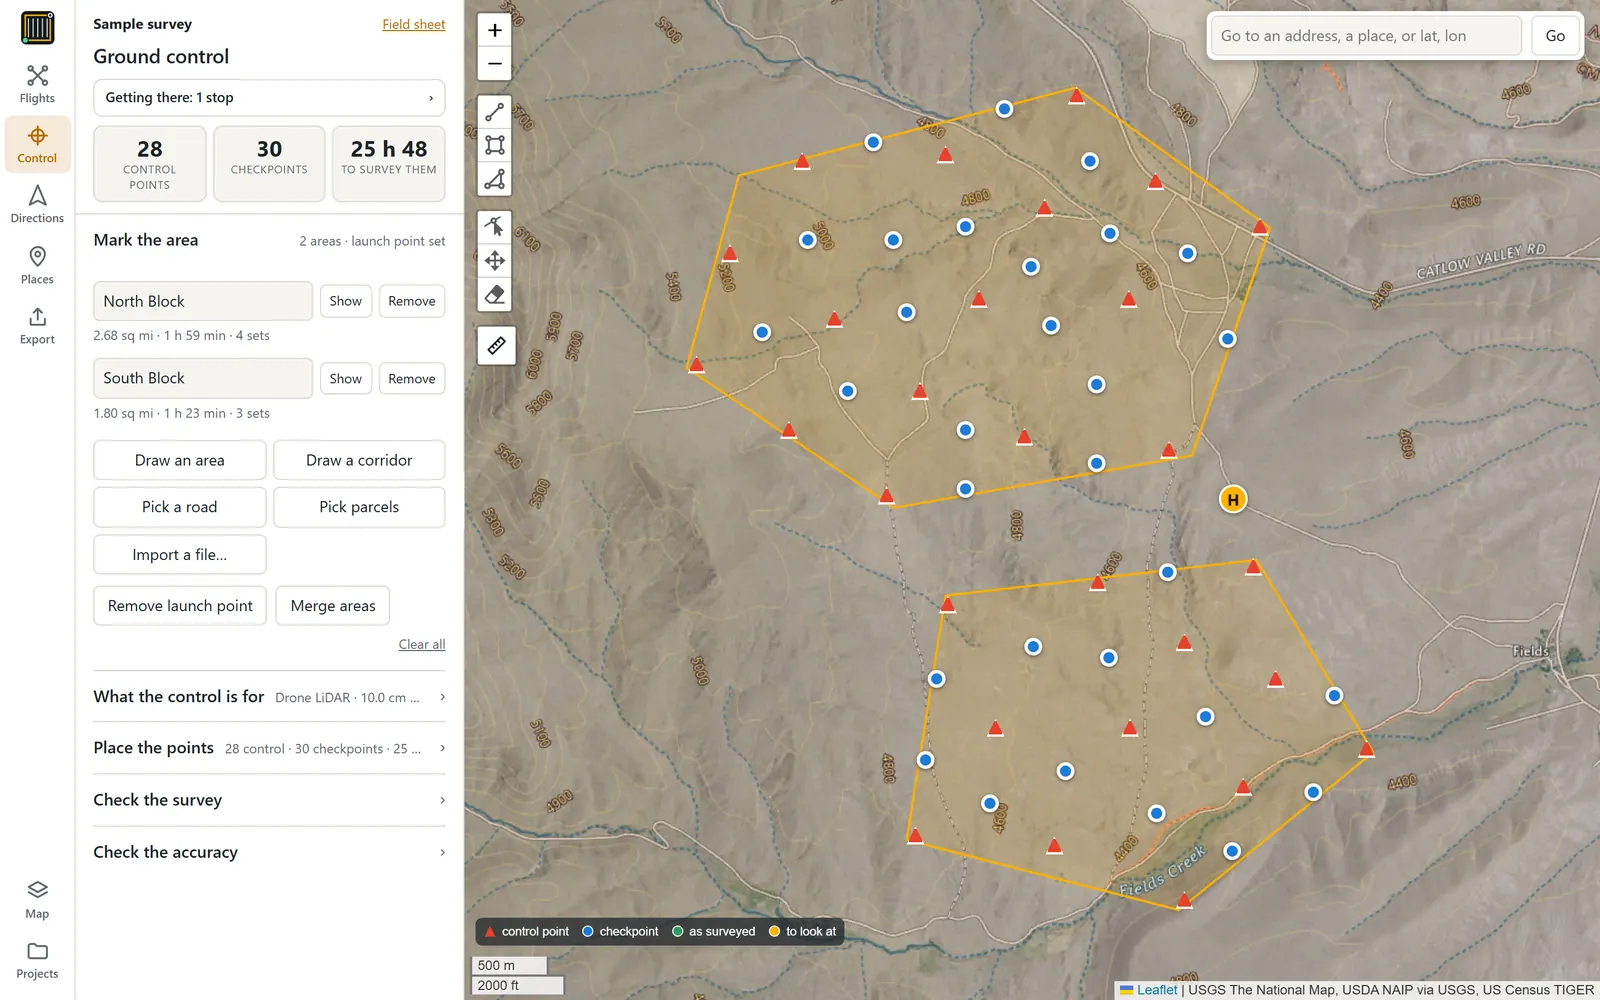
    A second section on the same map, beside Flights. Say what the control is for, a drone job or a Trimble MX60 drive, and how you will survey it. It tells you straight away whether that method reaches the accuracy the points need.

    Place the points
    Control points and checkpoints go on the map by the published rules, numbered in the order a crew would walk them. Drag any of them onto open, flat ground.
    Take them to the field
    Export the points for Trimble Access as CSV, or as KML or GeoJSON.
    Check the survey
    Open the file you bring back. It checks that every planned point was surveyed, and holds the precisions, repeat measurements, PDOP and satellites against what the job needs.
    Check the accuracy
    Open the checkpoints as measured in the product. It gives the RMSE per axis, flags what falls outside, says when the heights are shifted as a whole, and holds the result against the class.
    Swathwise with the Control section open. Two survey blocks on satellite imagery carry red triangles for control points and blue circles for checkpoints; the panel reads 28 control points, 30 checkpoints.
    Control points in red and checkpoints in blue, placed over a two-block job.
  5. Write the routes

    Swathwise writes the route files the aircraft flies: one DJI route file per block, named for it, ready to load into DJI Pilot 2. Each one is exported with terrain follow switched on and the ground under it packed inside the file, so the aircraft holds its height above the ground, not above the spot it took off from.

    only 16 m clear here takeoff without: 100 m above the takeoff point
    An illustration over made-up ground. Without terrain a route holds its height above the takeoff point, so rising ground comes up to meet it. With terrain it holds its height above the ground all the way.

    The ground comes from the U.S. Geological Survey's national elevation data, fetched when you export and stored in the file itself, so the controller needs no connection in the field. Areas, corridors and camera routes all get it.

    If terrain cannot be had - no connection, or a site outside the United States - the route is still written, flat, and Swathwise says so in red rather than letting a flat route pass for a terrain-following one.

    On the Matrice 300 and 350, LiDAR routes record on the scan lines only and pause through each turn. Corridor routes also import into DJI FlightHub 2.

    Still yours to do before it flies

    A route file is a draft until a pilot has checked it. Swathwise gets it most of the way; these are the steps it cannot do for you.

    1. Check the height profile on the controller

      Open the route in DJI Pilot 2 and confirm its height follows the ground. A flat profile means the terrain did not load.

    2. Look for what the terrain data leaves out

      It is bare earth at about 30 metres. Trees, buildings, towers, poles and wires are not in it, and neither is a sharp ridge or a cut bank. Walk or scout the site.

    3. Clear the airspace and the ground

      Airspace authorization, flight restrictions, weather, and permission to take off, land and fly over the land are the pilot's, every time.

    4. Set what a route file cannot carry

      A few settings live on the controller, not in the file. The field sheet lists them for your aircraft and sensor.

  6. Get the crew there

    Press Directions and the day's stops are already there, in flying order, with the route worked out from where you are standing. Change anything and it works the route out again. United States only.

    Swathwise with the Directions section open: fourteen stops listed in flying order, and the route drawn along the road on satellite imagery with each stop numbered. 14 miles, 1 hour 16 minutes.
    Fourteen stops in flying order along the corridor, routed by Swathwise's own directions server.
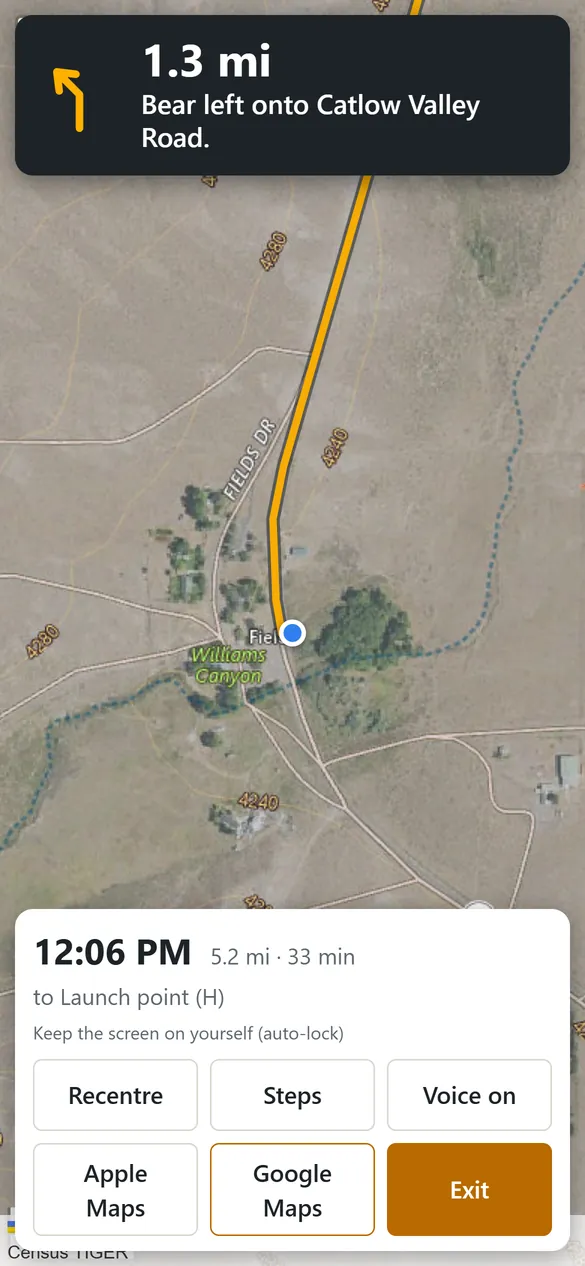
    Live navigation on a phone: a dark banner reads 1.3 miles, bear left onto Catlow Valley Road, above the route on satellite imagery.
    Live navigation on a phone.
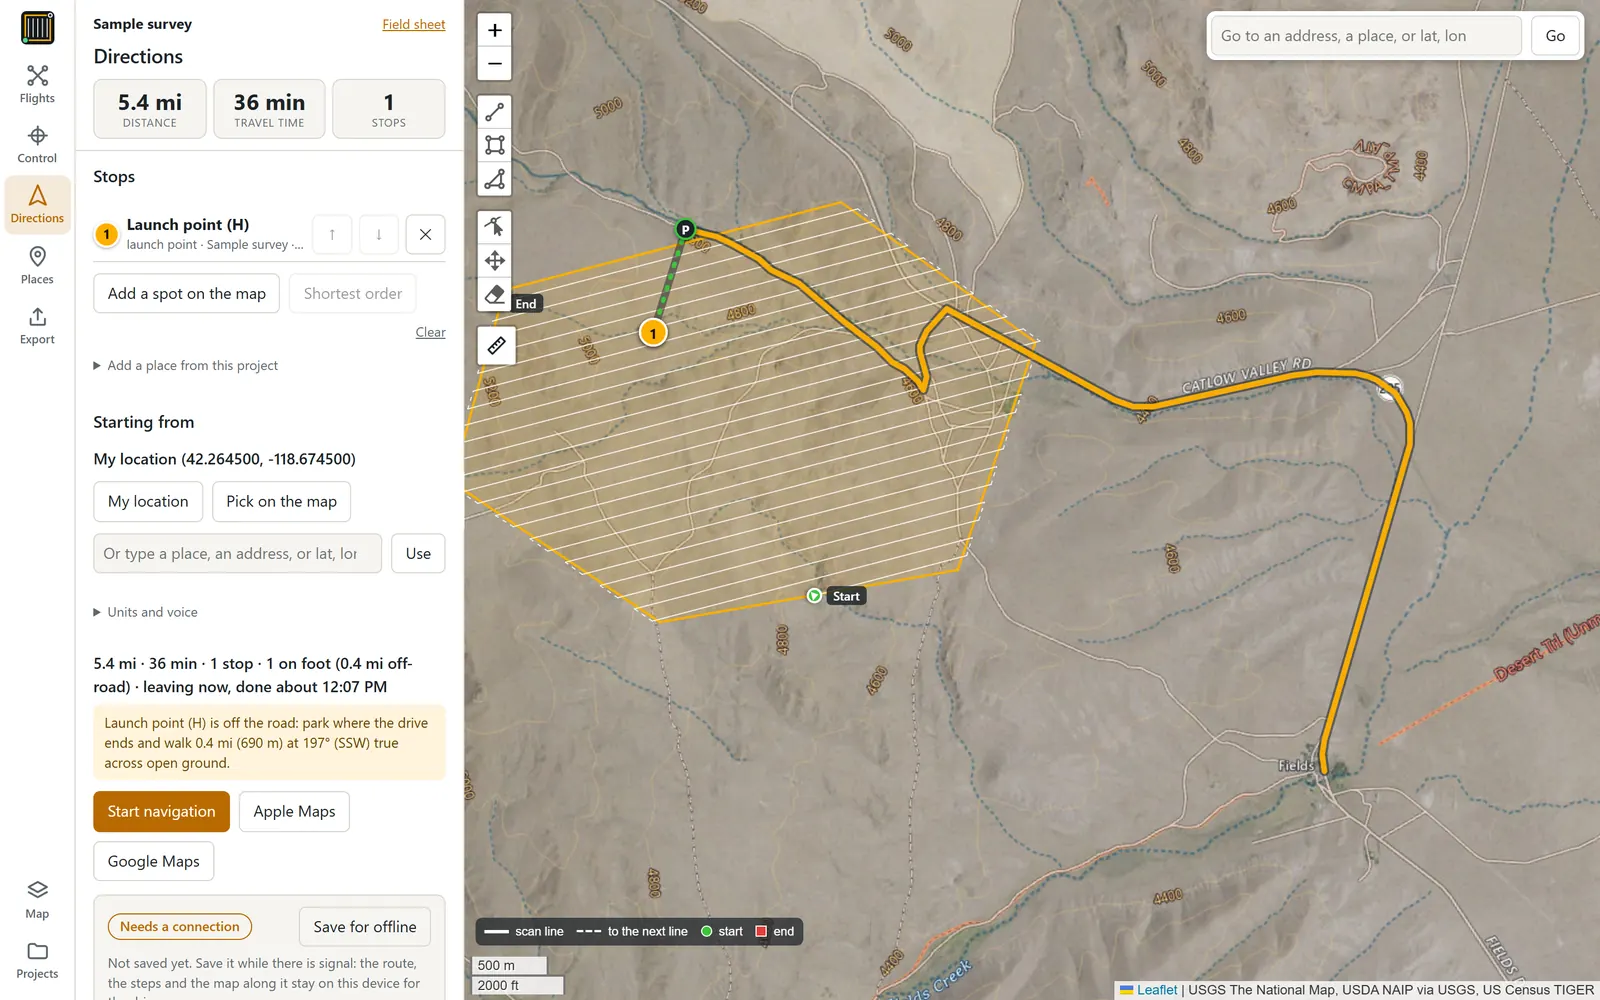
    A route that ends at a parking point marked P, then a green dotted walk to a launch point. The panel says to park and walk 0.4 miles at 197 degrees across open ground.
    A launch point off the road: park at P, then walk 0.4 mi at 197° across open ground.
    The day's stops
    Launch points, GNSS bases and control points, in the order you will need them. Reorder them, add a spot on the map, or press Shortest order.
    Walk-ins
    A stop off the road ends the drive at the nearest road, marked P, and adds the walk: its distance, its true bearing and the climb.
    Ways in
    Mark a path in Places as one to drive or walk, and Directions follows it up a private road no other map knows.
    Turn by turn
    On a phone: the next turn large, spoken turns and arrival time. Leave the route and it works out a new one, or shows the way back if there is no signal. Hand the drive to Apple Maps or Google Maps if you prefer.
    No signal
    Save the route for offline, and the steps and the map along the way stay on the device.
    On paper
    Directions as a PDF to print: an overview map, every step numbered, small maps at the turns that matter, and a box for emergency notes. GPX and KML for a GPS unit or Google Earth.
  7. Hand it over

    Beside the route files, everything Swathwise works out can leave with you as a document. The samples here were written by the app's own export code for the first example above.

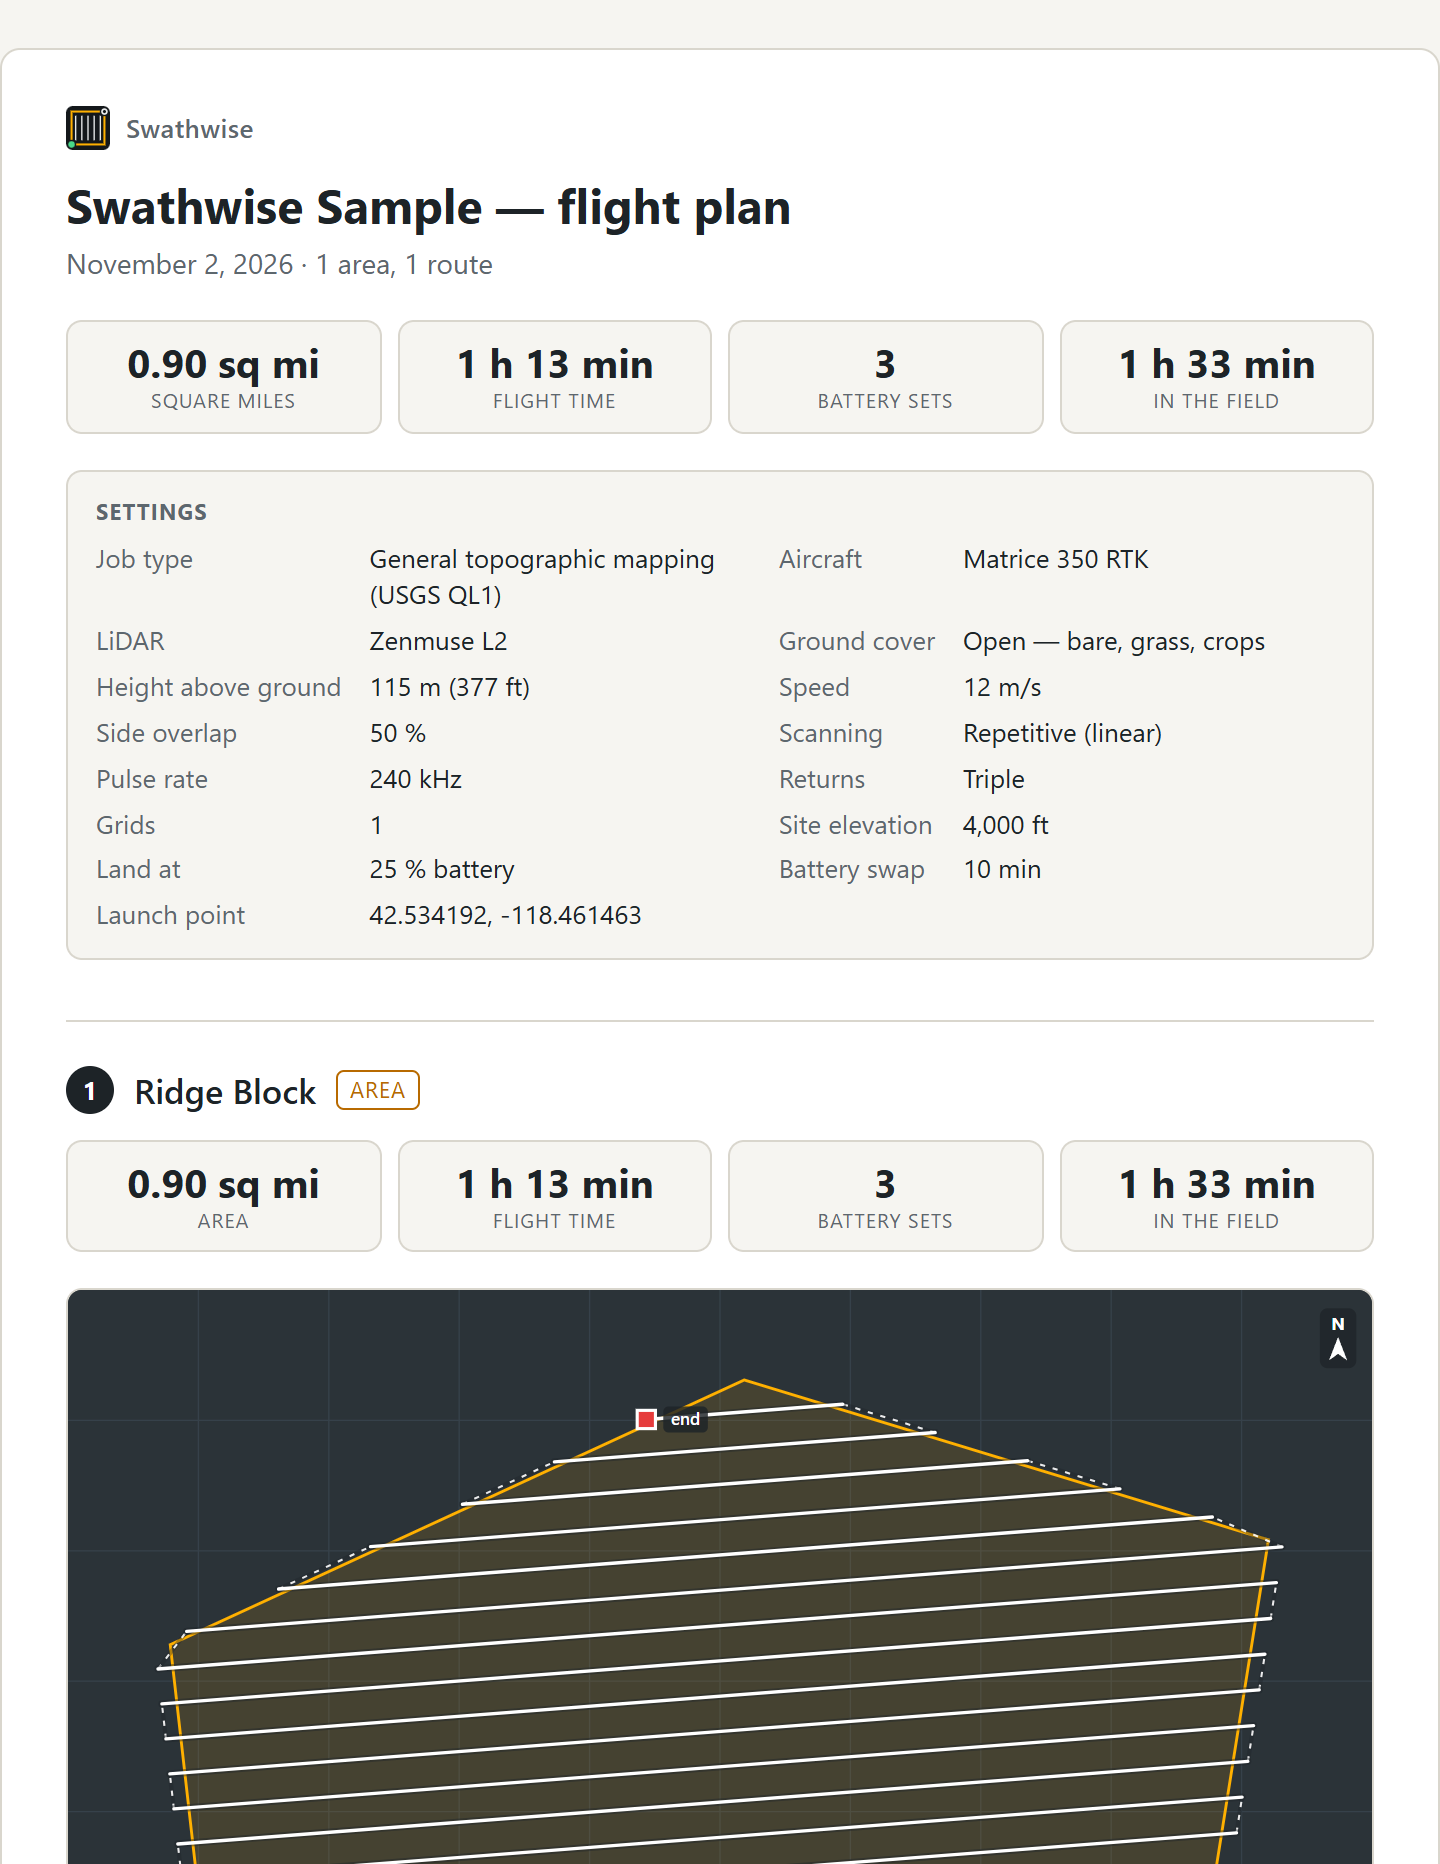
    The first page of a sample flight plan: totals for the job, the settings, and one area with its flight lines drawn to scale.
    • A flight plan you can print

      Totals, settings, then a page per area with its lines drawn to scale, the time, the battery sets, the route files by name and every warning. In the app the maps are drawn over aerial photos in the United States. It opens in any browser and prints to paper or PDF.

      Open the sample flight plan

    • An estimate for the quote

      One row per area: square miles, acres, flight time, battery sets, time in the field, line count and spacing, and the settings it was worked out at.

      Download the sample estimate (CSV)

    • Flight paths for Google Earth

      Every route's line in the order it is flown, with the boundary and the launch point. For looking at and showing a client, not for flying: the paths carry no heights.

      Download the sample paths (KML)

    • The same paths for GIS

      GeoJSON for ArcGIS Pro or QGIS, with heading, height, speed, line count and fly order on every path.

      Download the sample paths (GeoJSON)

    • Parcel boundaries

      Every lot the flight touches, with the assessor's fields, as KML or GeoJSON: for Google Earth, DJI Terra or a list for the landowner notices.

    • A field sheet for the truck

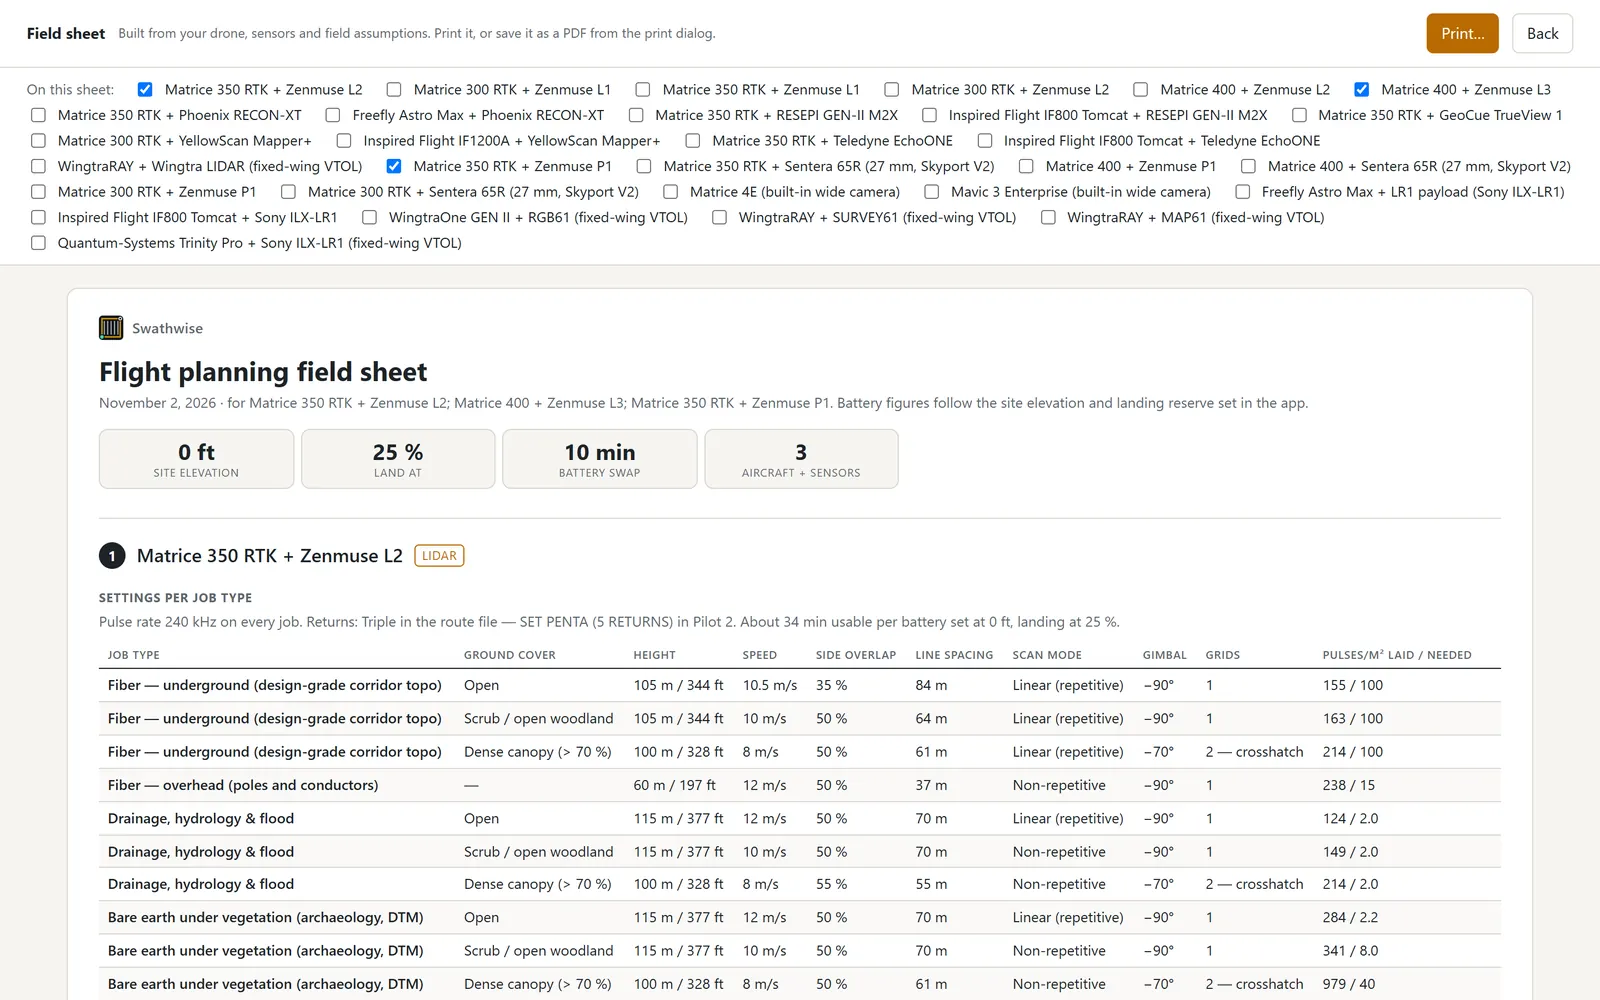
      A page to print for building a route on the remote with no laptop: your kit, the settings for each kind of job, and every box on the route screen.

    • Why there is no sample route file

      A route file is for flying, and a route over a sample area has no business in anyone's controller. The flight plan and the flight paths above show the same lines.

    A folder per project
    In the desktop programs every job gets a folder of source files, boundaries, estimates, flight routes and ground control. A changed export becomes V2 and nothing is overwritten.
    A whole folder on one map
    File projects under folders on the start screen, then show a folder on one map: every project in its own colour, with its areas, routes and launch point.
    The Swathwise field sheet on screen, with a table of settings per job type for a Matrice 350 RTK and Zenmuse L2.
    The field sheet: every figure comes from the same planner as the estimate.

Free, on everything you carry

Your boundaries, projects and exports stay on your machine, filed into a folder per project.

Once your maps are saved it works without a connection. When it is connected, the only things it fetches are map images, place-name search, ground elevation, the terrain for a route you export, directions you ask for, and its own updates. The privacy notice says exactly what each of those receives.

The same planner also runs in a web browser with nothing to install (app.swathwise.org), where Cloudflare counts the visit as it does on this website, and on iPhone and iPad from the App Store.

Swathwise is in working use on real survey jobs, and it is free: download it for Windows or Mac, get it for iPhone and iPad, or open it in your browser.

Get Swathwise Open it in your browser